Zhaoting Li
Zhaoting Li
PhD Candidate in Robot Learning at TU Delft
Cognitive Robotics, TU Delft
Netherlands

Hello!

I am a PhD candidate at the Department of Cognitive Robotics at TU Delft, where I work with Prof. Jens Kober and Prof. Cosimo Della Santina. My research focuses on robot learning, interactive imitation learning, and applying these techniques to real-world robotics problems, such as harvesting and performing everyday tasks.
Selected Publications

Full list on Google Scholar

Set-Supervised Diffusion Policy: Learning Action-Chunking Diffusion through Corrections
Zhaoting Li, Gang Chen, Javier Alonso-Mora, Cosimo Della Santina, Jens Kober
Robotics: Science and Systems (RSS), 2026
From Action Labels to Sets: Rethinking Action Supervision for Imitation Learning from Corrective Feedback
Zhaoting Li, Rodrigo Pérez-Dattari, Robert Babuska, Cosimo Della Santina, Jens Kober
arXiv preprint arXiv:2502.07645, 2025
Scalable Task Planning via Large Language Models and Structured World Representations
Rodrigo Pérez-Dattari, Zhaoting Li, Robert Babuška, Jens Kober, Cosimo Della Santina
Advanced Robotics Research, e202500002, 2025
Learning Robot Exploration Strategy with 4D Point-Clouds-like Information as Observations
Zhaoting Li, T. Li, J. Wang, M. Q.-H. Meng
IEEE Robotics and Automation Letters, 7(1), 1-8, 2022
Efficient Heuristic Generation for Robot Path Planning with Recurrent Generative Model
Zhaoting Li, J. Wang, M. Q.-H. Meng
IEEE International Conference on Robotics and Automation (ICRA), 2021

Experiences

PhD candidate
Cognitive Robotics (CoR), TU Delft
2023.09 - present (expected late 2027)
M.Sc. in Robotics, Systems and Control
ETH Zurich
2021.09 - 2023.06
Research Assistant (master program deferred due to COVID-19)
Southern University of Science and Technology (SUSTech)
2020.07 - 2021.07
Visiting student researcher
Mechanical Systems Control Lab, UC Berkeley
2019.07 - 2019.09
B.Eng. in Automation
Harbin Institute of Technology (HIT)
2016.09 - 2020.06

Projects

PhD research at TU Delft, published at RSS 2026 [paper] [code]

  • Proposed Set-Supervised Diffusion Policy (SDP), which trains action-chunking diffusion policies from human corrections by pairing the robot’s undesired action-chunks with the human’s corrective action-chunks.
  • Used these pairs to construct sets of desired action-chunks and trained the diffusion policy to imitate samples from these sets, instead of only imitating positive actions.
  • Outperformed standard Diffusion Policy on real-robot Insert-T and round-table assembly tasks, with the largest gains on harder initial states and better robustness to noisy data.

PhD research at TU Delft [arXiv] [code]

  • Showed that behavior cloning, which treats each human action as an exact label, is brittle when the labels are imperfect, especially for expressive models such as energy-based models.
  • Proposed CLIC, which uses human corrections to build and refine sets of desired actions and trains the policy to place probability mass over these sets, supporting both absolute and relative corrections and multi-modal behaviors.
  • Demonstrated in simulation and real-robot experiments (Insert-T, water pouring) that CLIC is competitive with state-of-the-art methods on accurate data and substantially more robust to noisy, relative, and partial feedback.
2022.10 - 2023.06

MSc thesis in Computational Robotics Lab (CRL), ETH Zurich; RSS 2023 workshop paper [paper] [video]

  • Implemented a contact detection algorithm that estimates contact locations and forces from joint torque sensor data.
  • Extended the contact particle filter method to output multiple possible solutions, generalizing the state-of-the-art method to multiple-contact cases.
  • Implemented a contact-aware control framework that keeps interaction forces over the robot’s whole surface below a safety threshold, for both soft and rigid contacts.
  • Extended the BiTRRT sampling-based planner to be contact-aware, and validated the framework on a Franka robot in a setup inspired by the Amazon stowing task.
Learning haptic data processing in Human Robot Collaborative Carrying Task
2022.03 - 2022.08

Semester project in Robotic Systems Lab (RSL), ETH Zurich [Report]

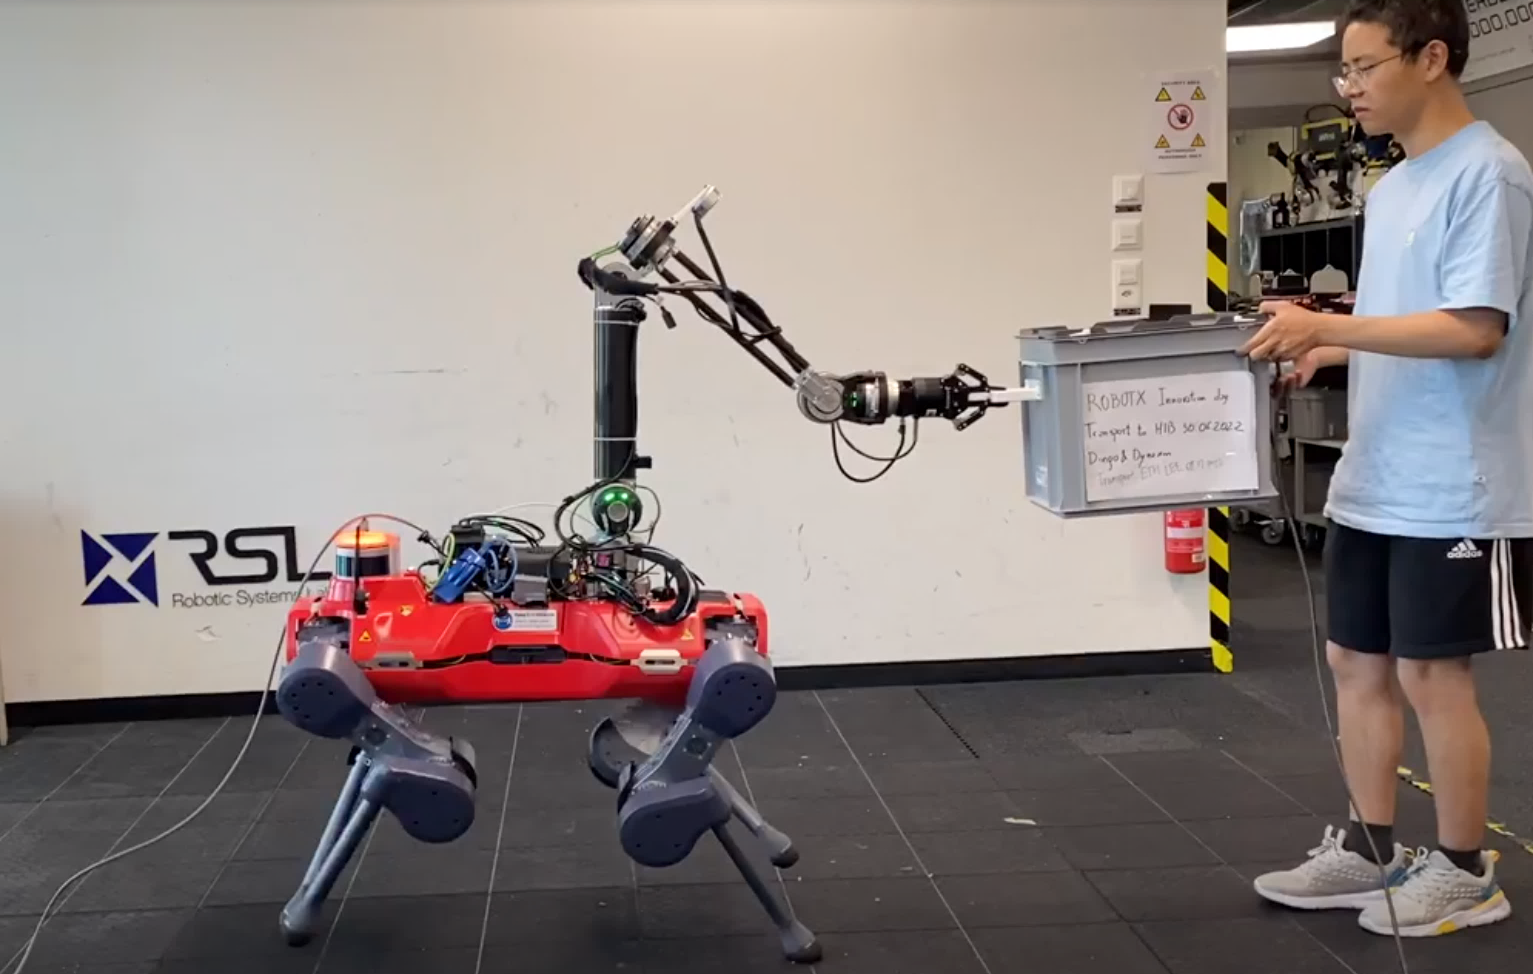
  • Proposed a learning-based force filtering method that uses the filtered-and-amplified robot-side forces as the ground truth, to reduce the noise introduced by the trotting action.
  • Designed an efficient transformer-based neural network, collected data during collaboration between humans and ANYmal with an arm, and trained the network in a supervised learning framework.
  • Tested the effectiveness of the proposed force filtering method with the admittance control framework.
Learning Multi-Robot Exploration Strategy with Adaptive-QMIX algorithm
2021.10 - 2022.02

Based on the robot exploration project

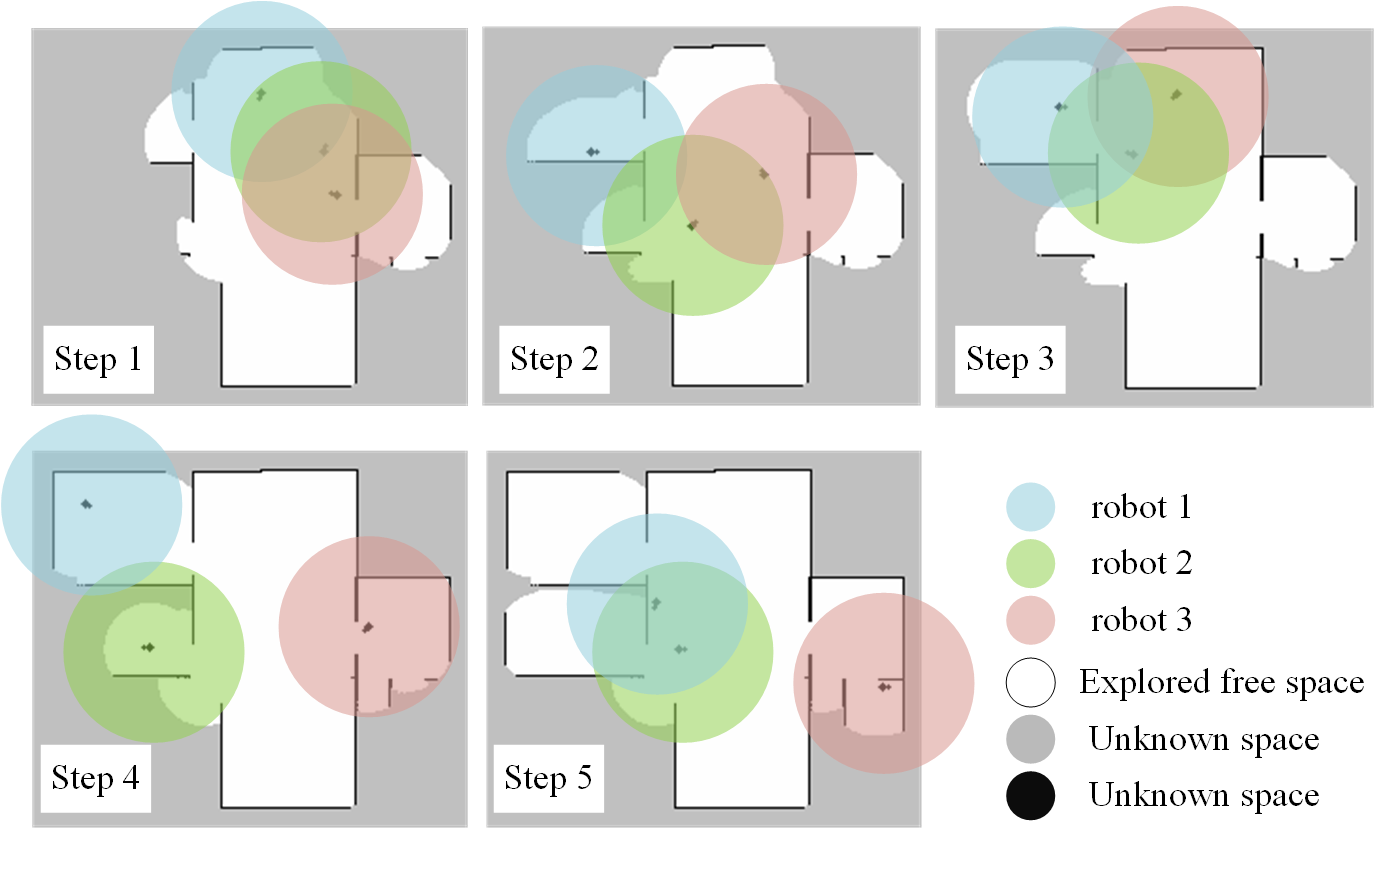
  • Developed the simulation environment for multi-robot exploration.
  • Proposed the adaptive-QMIX method, which adapts to a varying total number of robots.
  • Applied the proposed algorithm to the multi-robot exploration problem.
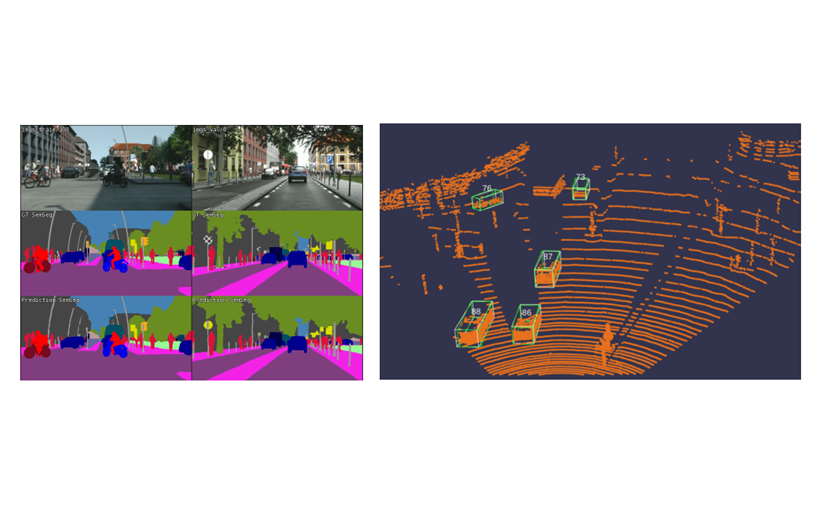
Deep Learning for Autonomous Driving: Multi-task learning and 3D object detection
2022.04 - 2022.07

Course project of Deep Learning for Autonomous Driving, ETH Zurich

  • Trained neural networks based on three types of multi-task learning frameworks, and compared the effects of different hyperparameters and structures.
  • Proposed an adaptive weight tuning method that dynamically adjusts the weight of each task’s loss during training.
  • Trained the baseline proposal refinement network, and proposed several methods to improve its performance.
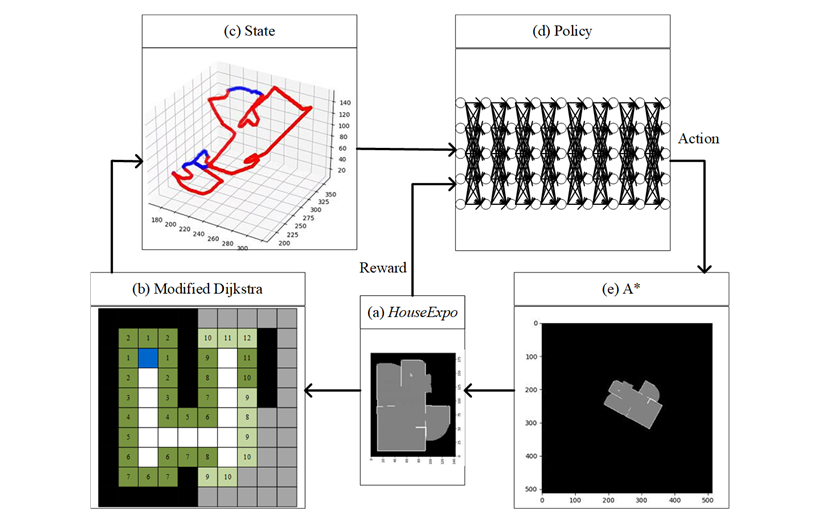
Learning Robot Exploration Strategy with Deep Reinforcement Learning
2020.10 - 2021.07

Research work at SUSTech, published at RA-L [paper].

  • Proposed 4D point-clouds-like information, which consists of 2D points’ location information, and the corresponding 1D frontier and 1D distance information.
  • Designed the corresponding training framework based on the deep Q-Learning method and modified it to adapt to the variable action space.
  • Demonstrated the performance of the proposed method on a wide variety of unseen environments, including maps much larger than those in the training set.
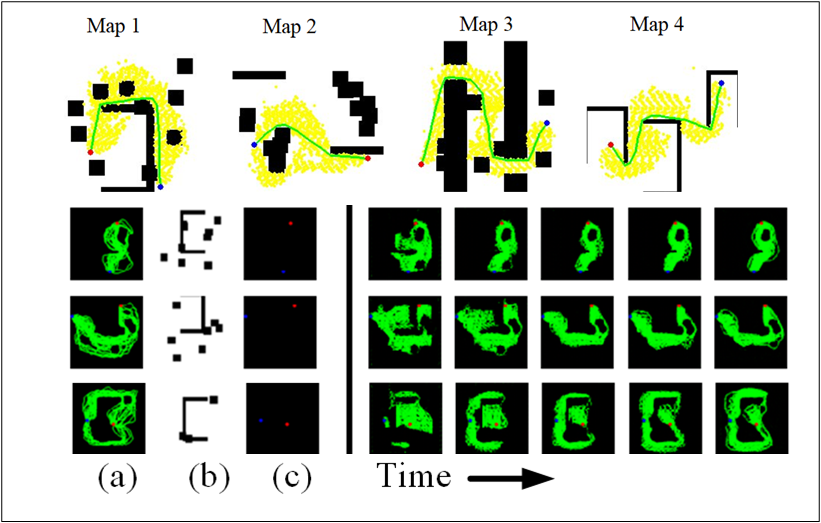
Efficient Heuristic Generation for Robot Path Planning
2020.07 - 2020.10

Research work at SUSTech, published at ICRA 2021 [paper].

  • Designed a novel recurrent generative model to generate efficient heuristics for robot path planning.
  • Incrementally constructed the heuristic through the feedback of historical information.
  • Combined the generated heuristic with the RRT* algorithm to guide it to find both initial and optimal solutions faster and more efficiently.
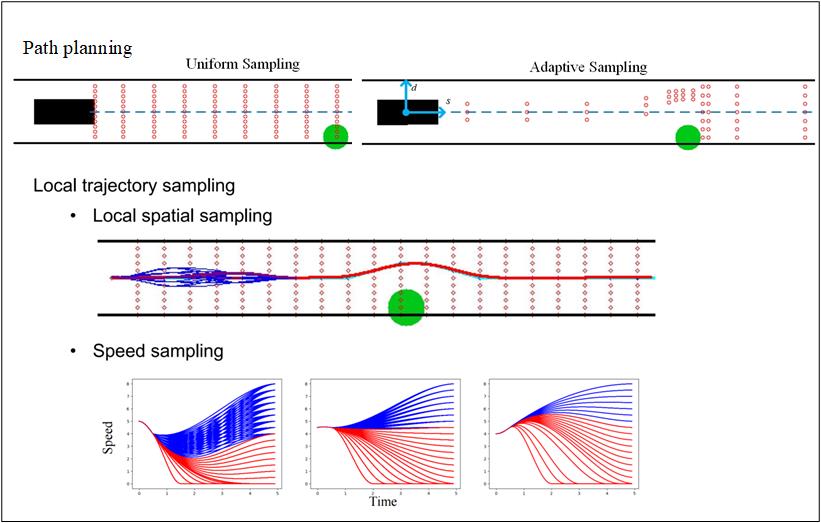
A sampling-based motion planning method for urban autonomous vehicles
2019.07 - 2020.01

Research work at UC Berkeley, published at IFAC 2020 [paper].

  • Applied the discrete elastic-band-based motion planning method (EB planner) to generate a piecewise-linear collision-free path with dynamic programming.
  • Employed a pure pursuit controller to smooth this path, and used a spatial and speed sampling method together with a cascaded ranking method to optimize the trajectory with many hierarchical features.
  • Applied a non-conservatively defensive strategy to avoid overreacting to threats with low probability.
  • Adaptively adjusted the sampling resolution based on the environment and the objectives of the ego vehicle.
A trajectory planning method for robot scanning system for scanning objects with unknown model
2019.02 - 2019.06

Research work at HIT, published at Neurocomputing 2020 [paper].

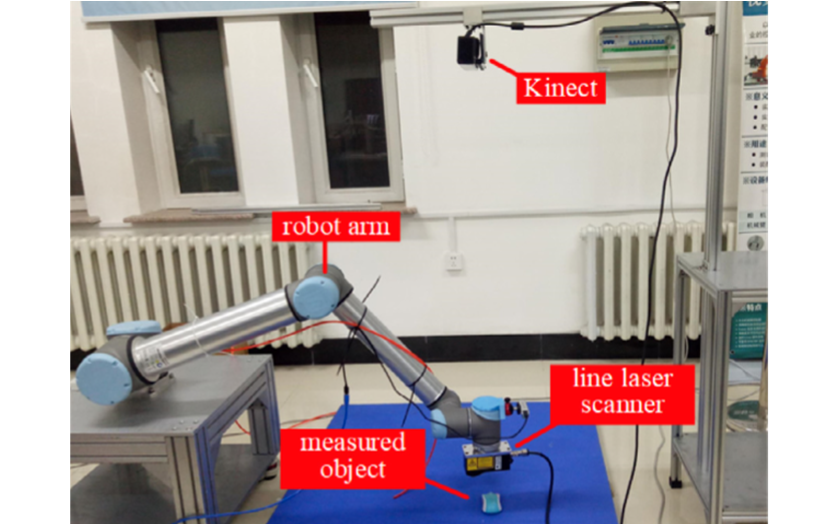
  • Designed an automatic and low-cost robot scanning system consisting of a Kinect camera, a UR10 robot and a line laser scanner, and calibrated the coordinate systems.
  • Proposed an online correction method based on follow-up control and scanned data to optimize the pose of the laser scanner.
  • Proposed a novel path planning method for laser scanning based on least-squares fitting and online correction, validated in many use cases under various working conditions.